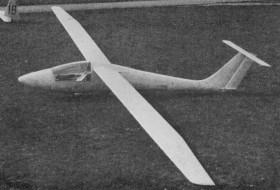
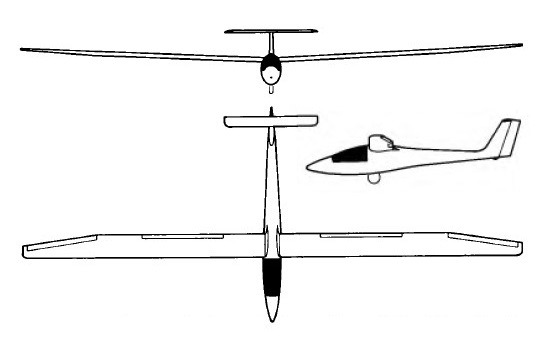
Designed by Alberto Morelli, the M-300 is a high performance single-seater intended not only for club use but for competition and record flying, and to this end particular attention has been paid to structural design and techniques both to reduce the time taken forcontruction and to ensure the necessary accuracy and quality of surface finish.
Only two prototypes of the M-300 were in the end built and flown at the CVT (Centro di Volo a Vela del Politecnico di Torino) at Turin, the first making its maiden flight in April 1968. The shoulder wings are of composite construction, the tapered wing spar being a machined aluminiumzinc alloy (-section beam with lightening holes in the web, and the ribs are milled out of a wooden sandwich, the wing skin being of thick pre-formed plywood panels. The fuselage is a semi-monocoque wooden structure with four main frames and nine stringers, and with a glassfibre nose cone; wing/fuselage attachment is by means of Redux-bonded dural fittings. The rudder is double-slotted and the all-moving tailplane on top of the fin is a narrow chord one-piece aluminium alloy structure. A retractable monowheel is provided.
Wing span: 15m / 49 ft 2.5 in Wing area: 9.16sq.m / 98.6 sq.ft Length: 6.39 m / 20 ft 11.52 in Empty Weight: 190 kg / 419 lb Gross Weight: 300 kg / 661 lb Water ballast: None Wing Load: 32.7 kg/sq.m / 6.69 lb/sq.ft Max speed: 155mph / 135 kt / 250 km/h Stalling speed: 38.5 kt / 71 km/h MinSink: 0.62 m/sec / 2 ft/sec at 49 mph / 45.2 kt / 79 km/h Best glide ratio: 38:1 at 55mph / 47.5 kt / 88 km/h Aspect ratio: 24.7 No. of Seats: 1
The construction of this plane dates back to January 1951 when Anton Cvjetković, a student of the third year of the Faculty of Technology in Zagreb, with the help of five faculty colleagues, was completed at the Radionice Airport in Croatia.
The first plane was designed at Marinkovićeva Street (Petrićeva op.a) where the Aerokluba chairman provided a studio apartment. There the hull and wings were built. In Zagreb it was a difficult time, it is not possible to purchase an engine for the plane. One of the friends had a used Volkswagen the engine was used.
The CA-51 aircraft is a wood unit intended to meet the level of amateur construction.
Construction was completed at the end of 1952. The first test flight was carried out by pilot Šuro Švarc on 19 November 1952 in Zagreb.
At the end of the VOC’s testing, the “Zagreb” Aeroclub is able to build five CA-51 aircraft. On one of the aircraft an additional fuel tank of 47 liters is fitted so that the range of 650 km is increased to 1,600 km. In the Zagreb-Bjelovar-Petrinja-Zagreb area, the pilot Berkovic flew about 1,200 km in 10 hours and 50 minutes with a speed of 110.8 km / h.
The constructor of the first aircraft emigrated to the USA in 1957 and there he set the further development of this aircraft, such as the 1961. the CA-61 aircraft with a Continental A65 engine, 47kW, and the 1965. the CA-65 with the Lycoming O-290-G engine of 92 kW.
YU-CMH No. 2 was located at a Museum in Belgrade.
CA-51 Engine: VW1000 cc, 22-hp at 3,000 rpm Prop: two-blade wood Wingspan: 8.40 m Wing area: 11.76 m² Length: 5.86 m Height: 2.00 m Empty weight: 211 kg Normal flight: 328 kg Fuel capacity: 39 lt Max. speed: 224 km / h Cruise speed: 127 km / h Stall: 60 km / h Range: 650 km Ceiling: 2,700 m Endurance: 5.5 h Fuel consumption 4.2 lt/hr Seats: 1 Cabin width: 1.3 m
The Bauman Aircraft Corporation adapted a B-290 airframe for the Custer ‘channel-wing’ as the Custer CCW-5. First flown in July 1953 at Oxnard, California.
USA. Set up during early 1950s to develop ‘channeling’ concept devised by its President, Willard R. Custer. (Wing contours formed semi-circular channel/duct in which two pusher engines were suspended). Small-scale experimental aircraft with this configuration flown December 1951; another test aircraft flew shortly afterwards. Followed by Custer CCW-5 (flown July 1953), a modified Baumann Brigadier (built by that company) with a channel wing and two Continental engines, and expected to take off in a few feet, rise vertically, hover and land vertically. First production model flew June 1964. Custer retired early 1968, but remained as consultant throughout prolonged certification program by DeVore Aviation Service Corporation. Despite its founder’s efforts to keep the company solvent, Custer Channel Wing Corporation eventually closed through lack of funds.
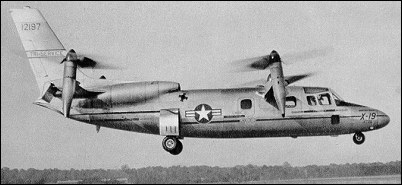
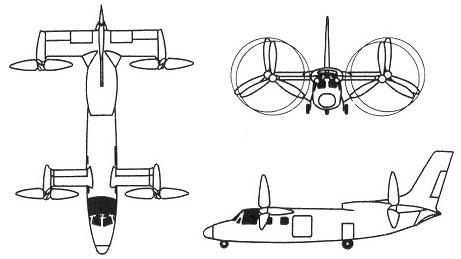
The Curtiss-Wright X-19 began as a commercial venture to develop a small, 4-passenger, executive VTOL aircraft that would have good high speed performance. Funded initially by Curtiss-Wright, it was designated the M-200. With solid test results from the X-100 confirming their theories regarding the potential for a practical application of radial lift, Curtiss-Wright pressed on with the design of the M-200. Design trade-off studies were performed which ultimately led to the X-19’s tandem wing configuration with a tilting propeller at each wing tip. The X-19 started with what Curtiss-Wright engineers felt was the optimal design for a propeller for a VTOL aircraft and then built the aircraft around it. The propellers had a very wide chord with a large amount of twist. This allowed them to maximize the amount of radial lift. At the start of the program, Curtiss-Wright funded the entire effort, with no interest in any government support. Two prototypes were being built when new management at Curtiss-Wright decided they no longer wanted to invest company research funds. They offered the two aircraft to the Tri-Service VTOL Program, a joint Air Force, Army, and Navy program office tasked with developing VTOL technologies for military needs. The Tri-Service Program also was developing the XC-142 and the X-22. Eighteen months later the Air Force agreed to buy the aircraft. When the Tri-Service Program bought the X-19s, the two prototypes already were 55 percent and 35 percent complete, with a substantial investment already having been made by Curtiss-Wright. The original X-19 design, as the M-200, was not built to any specific mission requirement. The goal was to fly as fast and far as possible and to be economically competitive with conventional executive transports that were becoming very popular in the 1960s. Analysis of the design showed that the M-200 could achieve a range of 1450km to 1850km with a maximum level speed of 740km/h at 4880m. It was to conform to FAA regulations, have all weather flying capability, low noise level, and be free of vibration. Conventional aircraft construction techniques and materials were used.
The X-19’s basic configuration was an all-metal, monocoque fuselage, with two shoulder-mounted tandem wings. A nacelle at each wing tip could rotate from pointing vertically for take off and landing to pointing horizontally for cruise. The wide, specially-designed propeller was mounted in front of each nacelle. Two turboshaft engines housed in the rear fuselage powered the four props. The fully hydraulic tricycle landing gear retracted completely into the fuselage. A large vertical tail was required because the props were located relatively close to the fuselage. Total height was just over 5m. The original fuselage was 12.5m long, but the cabin area was only 1.2m high, 1.4m wide, and 2.4m long. The passenger compartment was intended for four passengers, or 450kg of cargo. The cabin was pressurized to 4880m. All fuel was stored in the fuselage, aft of the passenger/cargo area. There were two 860 lt tanks and one 990 lt tank. The front wing had a 6.1m span with a narrow chord, while the rear wing had a 6.4m span with a greater chord. The rear wing had almost twice the area of the front wing. The wings had no incidence, dihedral, or sweepback. The front wing incorporated full span flaps, while the rear wing had inboard ailerons and outboard elevators, the ailerons being slightly larger than the elevators. The flaps on the front wing were directly coupled to the nacelle tilt angle, and the pilot could not control them independently. At hover, the flaps and elevators drooped to their full extension of 60 degrees to decrease the amount of wing area that was in the prop downwash. The location of the props on wing tips, however, resulted in the loss of 7 to 9 percent of lift due to wing interference. Curtiss-Wright intended originally to use four Wankel rotary engines rated at 580hp each. Curtiss-Wright eventually abandoned the Wankel in favor of two Lycoming T-55-5 turboshaft engines of 2200hp each (although some sources stated T-55-L-7 engines of 2650hp each). This more than doubled the total power, but retained the ability to operate with one engine failed, including performing vertical take-offs and landings. Switching from four engines to two also simplified the design by decreasing the engine interconnects, and changing to turboshaft engines eliminated the need for engine cooling. Power from the engines was distributed to the props by means of three-inch diameter drive shafts and seven gear boxes. The gear boxes consisted of one engine coupling box that coupled the two engines so that either could power the entire system, two T-boxes to transfer power from the fuselage shafts into the wing shafts, and four nacelle tilt gear boxes. The exhaust pipe from each engine joined in the fuselage so that only one pipe exited the rear of the aircraft. The 4m diameter props construction consisted of a steel shank, foam core, and fiberglass shell. The paddle-wheel shape allowed them to produce about 2.7kg of thrust per horsepower. Low prop noise was obtained because the maximum tip speed of 250m/s was well below sonic speed. The cockpit accommodated two pilots seated side by side. The aircraft could be flown from either seat, but the pilot-in-command seat was on the right, as in a helicopter. The cockpit resembled that of a conventional aircraft, with the cockpit visibility being very limited for a VTOL aircraft. The high instrument panel also restricted vision over the nose. Two one-foot square windows were located near the pilots’ feet, but were too small to be effective and later were modified into ram air inlets to provide additional cooling. Each pilot had a conventional stick, rudder pedal, and two throttles. Nose wheel steering was by means of a hand tiller controlled by the copilot. To minimize the clutter on the instrument panel, there was a single oil temperature gauge and single oil pressure gauge for all nine gear boxes. The pilot could select which component to monitor by rotating a 9-way selector switch to the desired component. To signal a problem, each gear box had a single warning light that indicated either high or low oil pressure, or the presence of metallic chips in the oil. If the light illuminated, the pilot had to rotate the 9-way switch to see the specific problem. When rotated to the vertical positions, the front nacelles rotated past vertical, to 97 degrees, meaning the thrust actually pointed slightly forward. The rear naceltes rotated only to 82 degrees with their thrust pointing slightly rearward. A tilt button on the control stick caused all nacelles to tilt together. Initially, the nacelle tilt rate was mechanized at 5 degrees per second. It was soon realized that this would have required a deceleration from 90km/h to hover in less than 5 seconds, resulting in 0.5g of longitudinal acceleration. This was too much, so the rate was reduced to 1 degree per second, resulting in a more reasonable 0.2g. Two independent hydraulic systems controlled the nacelle rotation and prop blade angles. If the automatic system failed, the pilot could rotate them manually using a hand crank. The crank required 570 turns to move the nacelles from end to end, and eventually was replaced with a motor. The Tri-Service Program required a few changes to convert the M-200 into the X-19. North American Aviation LW-2B ejection seats, which used a rocket catapult mechanism and ballistically deployed parachutes, were added. These seats could operate from zero altitude and zero airspeed up to 15250m and deploy fully within 0.5 second from seat firing. The seats ejected through the canopy. The fuselage was lengthened by 0.9m so that two more passenger seats could be added, bringing the total personnel load up to two pilots and six passengers. This increased the fuselage length to 13.5m. The cabin door was enlarged to 1.06m high and 1.17m long, and a rescue hoist was added. The resulting aircraft was a bit long for a six passenger aircraft, but this was attributed mostly to the engines and fuel tanks being located in the fuselage. The only difference between the two prototypes was that the second had better instrumentation and data recording, and also had a dummy refueling probe installed on the nose to evaluate probe and drogue in-flight refueling. Weight growth after adding the ejection seats and stretching the fuselage resulted in the useful load being reduced to 185kg. This allowed for only one pilot and fuel for 10 minutes of hovering. With two pilots, the hovering time was cut to 1 minute. However, there was still 270kg of unusable fuel because of the location of the fuel pumps inside the tanks. The pump position was changed to improve the amount of usable fuel. The X-19 was statically unstable in hover and in pitch and roll at low speed, mandating the addition of stability augmentation in both of these axes. Control by the augmentation system was limited to 30 percent of the pilots’ control authority, so the pilot could override it if necessary. No stability augmentation was needed for yaw. The system initially mechanized rate feedback, but initial testing showed this to be of little use to pilot. The system was changed to a rate plus integral of rate, which improved control for hover and low speed flight. The X-19 was test flown with the stability augmentation turned off. Although it was controllable by the pilot, the workload was unacceptable. All gear boxes were designed to absorb the power required to lift the aircraft at a maximum weight of 5540kg. Great difficulty was encountered in qualifying them, and very low life limits were established in order to conduct flight tests. The engine coupling gear box, which combined the power output of the two engines, was capable of absorbing 2,900 horsepower with both engines running, or 2500hp from only one engine. With each engine producing 2200hp (or 2650hp, depending on the reference), the gear box obviously could not absorb full power from both engines. In addition, it was limited to 50 hours of operation. Likewise, the nacelle gear boxes had estimated lives of 13-14 hours and were thus limited to 5 hours of operation. The problem was felt to be improper heat treating of the gears. Wind tunnel tests of the initial design indicated an unacceptably high amount of interference drag at the junctions of the wing/fuselage and wing/nacelle. Drag clean up measures were taken, and more wind tunnel tests were run to confirm the improvement. The rear wing had significant lift loss due to downwash from the front wing, but knowing this, it was compensated for in the basic design. Airframe structural tests revealed no major problems. Full scale static propeller tests were performed to evaluate and reduce download losses on the wing at hover. The intended design empty weight was 3600kg with a gross take-off weight of 5540kg. However, the empty weight grew to 4800kg and the gross take-off weight to 6160kg by the time the aircraft was built, thus reducing the useful load and placing greater stress on the gear boxes. Most of the weight growth came from the fuselage, wings, and power transmission system. It is safe to assume that Curtiss-Wright engineers started their fuselage and wing designs using standard practices for a conventionally configured aircraft, but stress analyses indicated weaknesses peculiar to the tandem design and prop locations. The fuselage had to be heftier than originally expected to handle the loads imposed by the landing gear location and the tandem wing configuration. The wings also had to be heftier than normal because during hover, all lift came from the props at the wing tips, rather than the lift being distributed along the wing as on a conventional aircraft. Also, the wings had to be very stiff so as not to transmit any propeller vibration. The shafting and gear boxes also proved to be heavier than predicted. Altitude was controlled during hover by the throttle, and precise control was difficult because of a lag of nearly one second in the engine response time. Varying the pitches of the four props controlled pitch and roll. A unique prop rotation scheme was used to maximize propeller torque for yaw control…the props on opposite corners turned in the same direction. A yawing moment resulted from the blade angle being increased on one corner and decreased on the opposite corner. The pilot didn’t control the blade angles directly, but used the rudder pedals for yaw and the stick for pitch and roll inputs. A mixer in the flight control system automatically controlled the actual commands to the individual props. To initiate a transition from hover to horizontal flight, the pilot pressed the tilt button on the stick to start the nacelles rotating, then added throttle to increase lift, accelerate, and maintain altitude or climb. As altitude and speed increased, the pilot continued to lower the nacelles until reaching 295km/h, at which time the transition was complete and the X-19 would fly like a conventional aircraft. Throughout the transition, the mixer continuously faded out prop control and faded in conventional control surface control as the airspeed increased. To reverse the transition, the process was reversed.
Roll out of the first prototype, tail number 62-12197, occurred on July 23, 1963. The flight test approach was to demonstrate hover, transition, and finally forward flight. Curtiss-Wright pilots would fly the initial flights, demonstrating hover and transition. After that, a Tri-Service test team would take over. The first flight was performed on November 20, 1963, at Curtiss-Wright’s facility at Caldwell, NJ. The X-19 lifted off for only a few seconds in hover before settling and collapsing a main gear because of side loads. Although the damage was minor, it was seven months until the X-19 flew again. The Air Force wanted to send the X-19 to Edwards AFB. Curtiss-Wright argued that supporting the test program at Edwards would be difficult, and that in an emergency, the X-19 would land vertically, making the long runway and large dry lake bed unnecessary and a waste of taxpayers’ money. The Air Force finally agreed that flights up through transition would be done at Caldwell, NJ, but the remainder of test flights would be performed at Edwards. Flight testing resumed on June 26, 1964. The X-19 made numerous hovers, most only a few seconds in duration. By August 7, it had flown on twelve different days and accumulated one hour and 37 minutes, accomplishing most of the objectives planned for its first eight hours of hover testing. The X-19 demonstrated spot turns, lateral translations at speeds up to 28km/h, rearward flight at 19km/h, forward flight at 37km/h, and 50 take-offs and landings. During these tests, the X-19 proved difficult to control, requiring excessive pilot workload. Various combinations of stick breakout and gradient forces were tried, but produced no improvement. However, the pilots were improving their skills at such a fast rate as they gained experience that it was difficult to determine if improved performance was from increased experience or the control system improvements. On the 21st flight, the stability augmentation system was turned on, which made hovering much easier. Flight speeds up to 160km/h were obtained with good flight characteristics up to this speed. On November 12, the X-19 experienced a full pitch hardover caused by the stability augmentation system. The pilot retained control because of the limited authority of the stability augmentation system and deactivated it. On the next day, they experienced a roll hardover. The cause of these incidents never was determined conclusively. On December 4, 1964, the X-19 suffered damage from loose cinders on the runway, which had just been resurfaced. Both engines and the leading edges on all four props were damaged. On January 31, 1965, one prop failed, which forced suspension of further testing for six months. While repairs were being made, it was decided that testing should be moved to the Federal Aviation Administration’s National Aviation Facilities Experimental Center (NAFEC) near Atlantic City, NJ. On July 31, 1965, the X-19 hovered for an air worthiness test after six months of down time, following which the props were removed and the aircraft was shipped to NAFEC. The X-19 was reassembled quickly and soon was flying again at NAFEC. Throughout August 1965, it made numerous high speed hovers going more and more into the transition. At this point, the Air Force test team joined the program. The Air Force test pilot quickly determined that the remaining control problems during hover were caused by excessive and uneven hysteresis in the control stick. Hysteresis is the tendency of the stick and control surfaces not to return to their original position when the pilot moves the stick then lets go (it is caused by friction between all the moving parts and stretching of control cables). Pitch hysteresis was found to be 4 to 8 percent of total displacement, and lateral hysteresis was 12 to 25 percent. Pilots had to make much bigger roll inputs than pitch inputs, resulting in poor control harmony and the pilot getting out of phase with the aircraft’s motions. This problem was corrected, and hovering became much easier. The first full transition was planned for August 25, 1965, on flight number 50. As the X-19 climbed and accelerated, the nacelles tilted as far as 65 degrees from vertical as the aircraft reached 150km/h at 400m. At this point, the temperature warning lights for left rear nacelle gear box and aft T-box illuminated. The pilots terminated the test and began a return to the airport. An immediate, emergency landing did not appear warranted, and the pilots planned a normal approach based on the recommendation from the ground support team. As they circled to line up with the preferred runway, a very high frequency vibration and a low frequency random shake began. Lateral control began to deteriorate. With the X-19 pointed toward a wooded area at low altitude and fearing that they would not clear the trees, the copilot jammed the throttles forward. As they climbed and accelerated, some control was regained and the vibrations smoothed out. At 120m, the left rear prop snapped off, and the X-19 rolled to the left and pitched up. This was followed promptly by the separation of the left front prop, then the two right props. The pilots bailed out inverted, their parachutes deploying fully within 2 seconds at an altitude of 70m. The aircraft crashed into a nearby swampy area and was totally destroyed. The pilots suffered only minor injuries, mostly cuts from ejecting through the canopy. The time from loss of props to ejection was only 2.5 seconds. The cause of the crash was attributed to the copilot’s applying full power. The drive system could not absorb the 4400hp being generated, resulting in the failure of the prop gear box. Total flight time for the flight was only seven minutes.
The crash itself did not end the X-19 program. The Air Force wanted to continue with testing the second prototype, which was nearing completion, but wanted to switch to a fixed price contract. Curtiss-Wright did not like that, because they would now take all financial risk. Their management also saw no future business in a commercial VTOL transport, even if the X-19 ultimately proved successful. They refused the Air Force’s offer. Unable to come to any agreement, the program ended in December 1965.
The X-19 completed 129.4 hours ground running time and flew a total of 3.85 hours. The second X-19 never flew and eventually was cut up for scrap.
Curtiss-Wright X-19A Engines: two 2,200-shp (1640-kW) Avco Lycoming T55-L-5 turboshafts Wingspan: 10.5m Length: 13.5m Height: 5.2m Wing area: 14.4 sq.m Take-off weight: 6200kg Empty weight: 4400kg Max speed: 720km/h Cruising speed: 650km/h Range with max fuel: 1200km Crew: 2 Passengers: 4 Payload capacity: 550kg
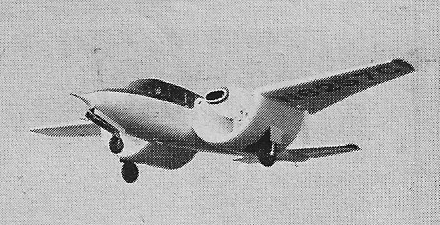
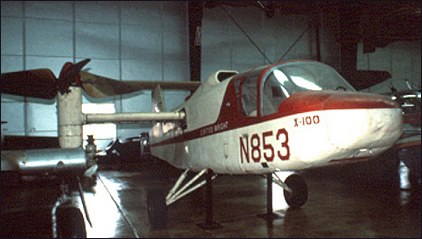
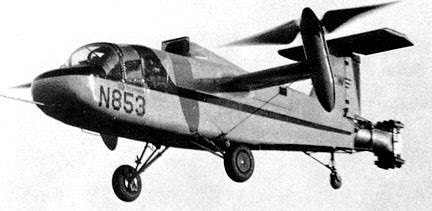
The Curtiss-Wright X-100 was a short-lived research program used to demonstrate the lift concept being developed for the Curtiss-Wright M-200 aircraft, which eventually became the X-19. The X-100 was to test the lift force concept and the gimbaled nacelles needed for a tilt prop configuration, and to test the glass fiber propellers needed to enable the use of radial lift. The X-100 was successful in that it verified the characteristics of the props, and produced data on noise, vibration, downwash, ground effect, stability, and control, and the piloting techniques needed to hover and transition a tilt prop VTOL. The airframe was all aluminum except for the aft half of the fuselage starting just aft of the cockpit, which was fabric covered. Design and fabrication was completed in just over a year, using concurrent design and construction. The design, fabrication, testing, and documentation of components occurred in a continuous and ongoing process. The X-100 was a high wing with T-tail and conventional landing gear. The fuselage was 8.6m long and consisted of welded tube construction. The shoulder mounted wing, with a span of 4.9m and an area of 2.1sq.m, had a wing loading of 560kg/sq.m. This was intentional so that the radial force produced by props could be demonstrated beyond any doubt. A three bladed, 3m diameter propeller was mounted on a gimbaled nacelle at each wing tip, and the two props rotated in opposite directions to balance yawing moments. Gross weight was 1580kg. The two-place cockpit had side by side seating. A rectangular engine intake was just behind the cockpit on the top of the fuselage. The T-tail, with an area of 2.1sq.m, was chosen to keep the stabilizer out of the props’ slipstream, giving the X-100 an overall height of 3.28m. To control pitch and yaw during hover, the engine exhaust was ducted out the rear of the fuselage and could be vectored up or down, and left or right by a device called a jetivator. This device was chosen for simplicity and to reduce weight. As a control effector, the jetivator could produce 63kg of pitch force and 18kg of yaw force. Roll control during hover was by differential control of the prop pitch. Altitude control was by means of the throttle. The X-100 originally had a rigid conventional landing gear. It eventually was replaced by tricycle gear to improve landing characteristics. The props were made of foamed plastic molded onto a metal shank and covered with a layer of urethane elastomer. Blades were wide and had a considerable amount of twist to maximize the amount of radial lift. The relatively low tip speed of 200m/s in hover minimized the amount of noise. The nacelles could rotate from pointing vertical to 12 degrees above horizontal. They rotated forward slowly at 2 degrees per second to allow the pilot to adjust power and attitude in order to prevent settling during the transition to cruise flight. They rotated back to vertical at 5 degrees per second. Curtiss-Wright’s program managers selected a Lycoming YT-53-L-1 turboshaft engine of either 650 or 825 horsepower. The U.S. Army, who had numerous YT-53-L-1 engines on hand, loaned two of them for the X-100 project. In exchange, Curtiss-Wright agreed to write a report on the engines’ performance. The fuselage had to be enlarged to accommodate the Lycoming engine. The design process started in February 1958. The first prop assembly was fabricated soon after and tested in NASA’s 12m x 24m wind tunnel starting in October 1958. It was run through the expected power operating range and at shaft angles from 0 to 90 degrees. These tests demonstrated that thrust in hover would be 10 percent below prediction (which was later confirmed in flight test), but there was enough excess thrust that the 10 percent loss was acceptable. Preliminary wind tunnel tests using models were performed at the Massachusetts Institute of Technology, then a powered model was run in the wind tunnel to determine stability and control characteristics. Tests using the actual aircraft eventually were run in NASA’s 12m x 24m wind tunnel. Reasonable correlation was achieved between wind tunnel tests and flight tests. Roll out of the completed X-100 was on December 22, 1958, at Curtiss-Wright’s Caldwell, NJ, facility, and the first engine run was performed on January 14, 1959. The first hover was made in a tether rig on April 20, 1959, to verify control power and feel. The first free hover test was performed on September 12, 1959, but extra weight was added to prevent the X-100 from getting out of ground effect. After three days of testing, hover flights of up to 20 minutes duration were made. The outflow velocities of air along the ground at various distances from the hovering X-100 proved to be similar to those of a helicopter of similar weight. Hover proved to be difficult as the pitch and yaw thrust provided by the jetivator was insufficient. Roll and yaw motions tended to couple together. The throttle was used to maintain height during hover, and lags in the engine response further compounded the problem. The X-100 also tended to weathervane into the wind during hover due to yaw moments produced by the wind hitting the props at an angle, which the jetivator’s yaw control could not counter adequately.
X-100 N853
Steady hovering was possible only up to about 4m, while the X-100 was in ground effect. If maximum power was applied on the ground, the X-100 would rise to about 7.6m, settle to within a few feet of the ground, then rise again and repeat several cycles of a slowly damped oscillation in height. The first transition from hover to forward flight was made on April 13, 1960. The transition itself was fairly simple. The pilot pressed a switch on top of the control stick to rotate the nacelles forward, then added power to prevent sinking. As the nacelles rotated, the X-100 picked up 30km/h of airspeed for each 10 degree of tilt. The conversion was done at 0.9 to 1.5m of altitude and very slowly to prevent settling to the ground. The nacelles were rotated down in 5 degree increments until a speed of 290km/h was achieved with the nacelle at a 15 degrees from horizontal. In general, low speed flight characteristics were unsatisfactory, especially in gusty air. The X-100 demonstrated a high pitch-up moment as forward speed increased, but directional stability, roll control, and longitudinal maneuvering were good in flight at 110km/h. At low altitude and up to 110km/h, the X-100 was notably free of mechanical vibration. Testing at altitude showed the aircraft to be buffet and stall free over a large range of angles of attack. STOL take-offs and landings were made with nacelle angle at 20 degrees from the vertical. Directional control was poor and was a problem during ground run. Smooth touch-downs also were difficult, much of the problem being caused by the landing gear being too stiff. There was considerable bouncing even at low touchdown speeds. The basic test program was completed on July 21, 1960. Test pilots from NASA visited Curtiss-Wright and flew the X-100 on August 12 and 13. This concluded test operations for the X-100 at the Caldwell, NJ, facility. With Curtiss-Wright satisfied that they had proven the radial lift concept, they turned the X-100 over to NASA. It was shipped to the Langley Research Center in October of 1960. It was used to study the effects of downwash on several types of ground surfaces, such as snow, grass, pavement, and packed dirt. NASA also studied problems associated with visibility in snow during hover and slow forward transition. This role was finished by October 1961.
The X-100 was test-flown until August 1965, when a gear case and prop failed. The pilots safely ejected and the ship crashed, but its technology was basis for X-200 and, ultimately, Bell-Boeing XV-22 Osprey.
Following the completion of tests at Langley, the X-100 was donated to the Smithsonian Institution. During its short career, the X-100 completed a total of 14 hours flying time and 220 hours of ground engine run time. It successfully proved the radial force concept, the feasibility of tilting nacelles, and low noise levels.
Formed from merger on August 9,1929 between Curtiss Aeroplane and Motor Co Inc. and Wright Aeronautical Corporation. Subsequent production mainly by Curtiss Airplane Division of Curtiss-Wright (aircraft still being “Curtiss” types rather than “Curtiss-Wright,” except for those with “CW” designations. In August 1929, stock changed hands, and the Curtiss Wright Corporation be¬came the controlling power in Travel Air. Travel Air’s production had been one ¬tenth of the total U. S. output of commercial airplanes. In 1936 complete reorganisation dissolved all main subsidiaries except Wright Aeronautical Division. From 1930 onwards main products included F9C Sparrowhawk fighter, carried on board USN airships; F11C/BFC Goshawk for USN and export versions Hawk I/ II/ III/ IV; SBC Helldivers for USN; SOC Seagull for USN; BT-32/ CT-32/ T-32 Condor bomber and civil/military transport; A-8/10/12 Shrike for USAAC; P-36 for USAAC and export Hawk 75s; one CW-20 prototype (later used by BOAC); C-46 Commando (USAAF) and R5C (USN) transport developments of CW-20; CW-21 Demon fighters; SNC trainers for USN, developed from CW-21; P-40 Warhawk/Tomahawk/Kittyhawk fighters for USAAF and other Allied services, of which 13,738 built during Second World War; C-76 Caravan transports for USAAF; O-52 Owl observation biplanes for USAAF/USN; SO3C Seamew for USN and Fleet Air Arm; SB2C Helldiver; AT-9 Jeep twin-engined trainers for USAAF; SC Seahawk scout seaplanes for USN; Republic P-47 Thunderbolt fighters for USAAF. Total wartime production (1940-1945) was 26,755 aircraft and 223,036 aero engines. After the war many Curtiss factories closed and most aircraft construction discontinued. Some Boeing B-29 modification undertaken until end of 1945, but Curtiss- Wright basically then undertook overhaul and repair of aircraft and manufacture of components, subassemblies and spare parts. By 1952 was concerned exclusively with production of aero engines and propellers. At the end of the 1950s Curtiss-Wright made a brief return to aircraft production with Skydart rocket-propelled target drone and prototype VZ-7AP VTOL “Flying Jeep” for Army trials. Last type produced by the company was the X-19A, a six-seat convertiplane with twin engines driving tandem pairs of tilting propeller/rotors; first flight June 26,1964, but development discontinued 1966. By 1970s main activities of the corporation included nuclear research, data transmission, and research into new advanced engine designs for USAF and NASA, although still made components for Boeing 747 airliners. The Aerophysics Development Corporation was absorbed by Curtiss Wright Corporation and became its Santa Barbara Division.
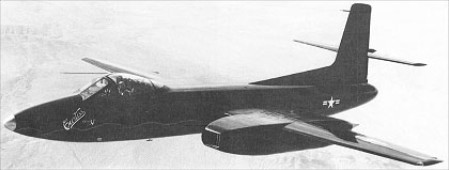
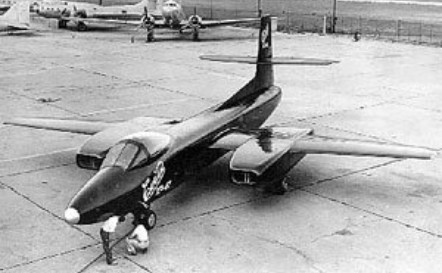
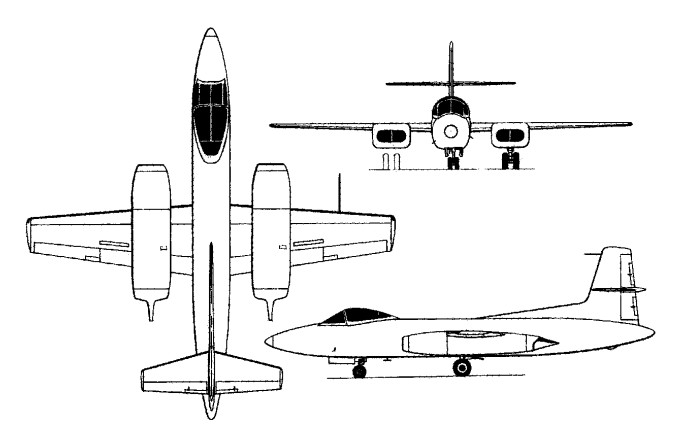
Curtiss had obtained tentative approval to build a twin-jet ground-attack aircraft, the XA-43. On 21 November 1945, this project was redirected towards completion of the Blackhawk fighter, mid-wing, four-engine craft with a two-man crew in side-by-side seating and with large fuel capacity. Powered by four 1360kg thrust Westinghouse XJ34-WE-7 turbojets, the sole XF-87 was flown at Muroc Dry Lake, California, on 1 March 1948 following long delays in its development and shipment from the company’s plant (later sold to North American) in Columbus, Ohio. The two prototypes were S/N identifiers as the 45-59600 and the 46-522. The 46-522 was modified to become the single XF-87A production aircraft.
The XF-87 proved to be underpowered. In the expectation that a different powerplant arrangement would make the Blackhawk more competitive, the twin-engine scheme was resurrected. On 10 June 1948, the USAF awarded a contract to Curtiss for 57 production F-87As to be powered by two 2722kg thrust each General Electric J47-GE-7 engines located in pairs on each wing. A further order was placed for 30 RF-87A reconnaissance aircraft.
The design featured four 20-mm cannon in a fixed nose installation and would have been fitted with a nose turret developed by the Glenn L. Martin Company which revolved in a 60-degree arc enabling four 20mm guns to be fired at any angle from zero to 90 degrees from the centre-line. Though the Blackhawk was able to overcome teething troubles in flight tests and seemed to offer promise as an all-weather interceptor, Curtiss was suffering from management difficulties and Northrop was developing an interceptor with solid potential, the F-89 Scorpion. On 18 October 1948, the USAF cancelled the F-87 Blackhawk programme in favour of the F-89. A second prototype which would have evaluated the twin J47 installation was never completed. It was to be the last Curtiss fighter.
The first aeroplane was known as the Nighthawk and powered by four Westinghouse J34-WE-7 engines, while the second was known as the Blackhawk and powered by four General Electric J47-GE-15 engines, the XP-87 Nighthawk flew. The Nighthawk and its Blackhawk counterpart were later be scrapped.
Curtiss-Wright XP-87 / XF-87 Nighthawk Engines: 4 x Westinghouse XJ34-WE-7 turbojet, 3,000lbs thrust Wingspan: 18.29 m / 60 ft 0 in Length: 19.15 m / 62 ft 10 in Height: 6.1 m / 20 ft 0 in Wing area: 55.74 sq.m / 599.98 sq ft Maximum Speed: 585mph (941kmh; 508kts) Maximum Range: 1,000miles (1,609km) Service Ceiling: 40,000ft (12,200m) Proposed armament: 4 x 20mm cannons in remote-controlled nose turret. 2 x 12.7mm machine guns Crew: 2 Empty weight: 11760 kg / 25926 lb Maximum Take-Off Weight: 49,833lbs (22,604kg)
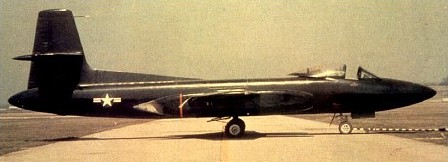
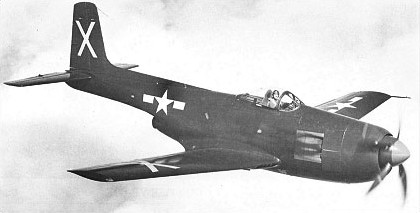
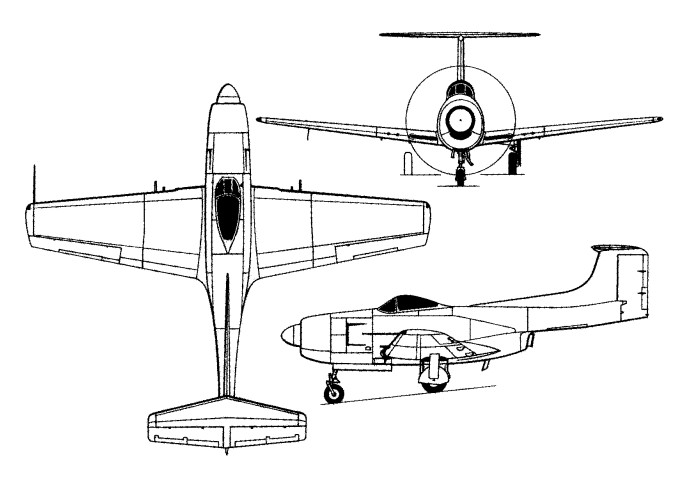
US Navy interest in the mixed-power concept for shipboard fighters had resulted in orders for three prototypes of the Ryan XFR-1, and 100 production FR-1s. Taken a stage further, on 7 April 1944 a contract for three prototypes of the more powerful XF15C-1 was placed with Curtiss. This was to be powered by a 2,100hp Pratt & Whitney R-2800-34W 18-cylinder two row radial in the front with a four-bladed propeller and a 1226kgp Allison-Chalmers J36 (Halford H-1B) turbojet in the belly. Armament was to comprise four wing-mounted 20mm cannon. The first XF15C-1 was flown on 27 February 1945, without the turbojet installed, this fitted by April, but the aircraft was lost on 8 May when it crashed during a landing approach. The second XF15C-1 flew on 9 July 1945, and was joined soon after by the third, both subsequently having their low-set horizontal tail surfaces replaced by a T-tail arrangement. The flight test programme continued until October 1946, by which time the US Navy had lost interest in the mixed power arrangement and cancelled further development.
Engines: 1 x Pratt & Whitney R-2800-34W 18-cylinder two row radial, 2,100hp / 1566 kW and 1 x Allison-Chalmers J36 (Halford H-1B) turbojet, 1226kgp / 2700-lb Max take-off weight: 7543 kg / 16630 lb Empty weight: 5 737 kg Wingspan: 14.63 m / 47 ft 12 in Length: 13.41 m / 43 ft 12 in Height: 4.65 m / 15 ft 3 in Wing area: 37.16 sq.m / 399.99 sq ft Max. speed: 469 mph / 755 km/h Range: 2228 km / 1384 miles